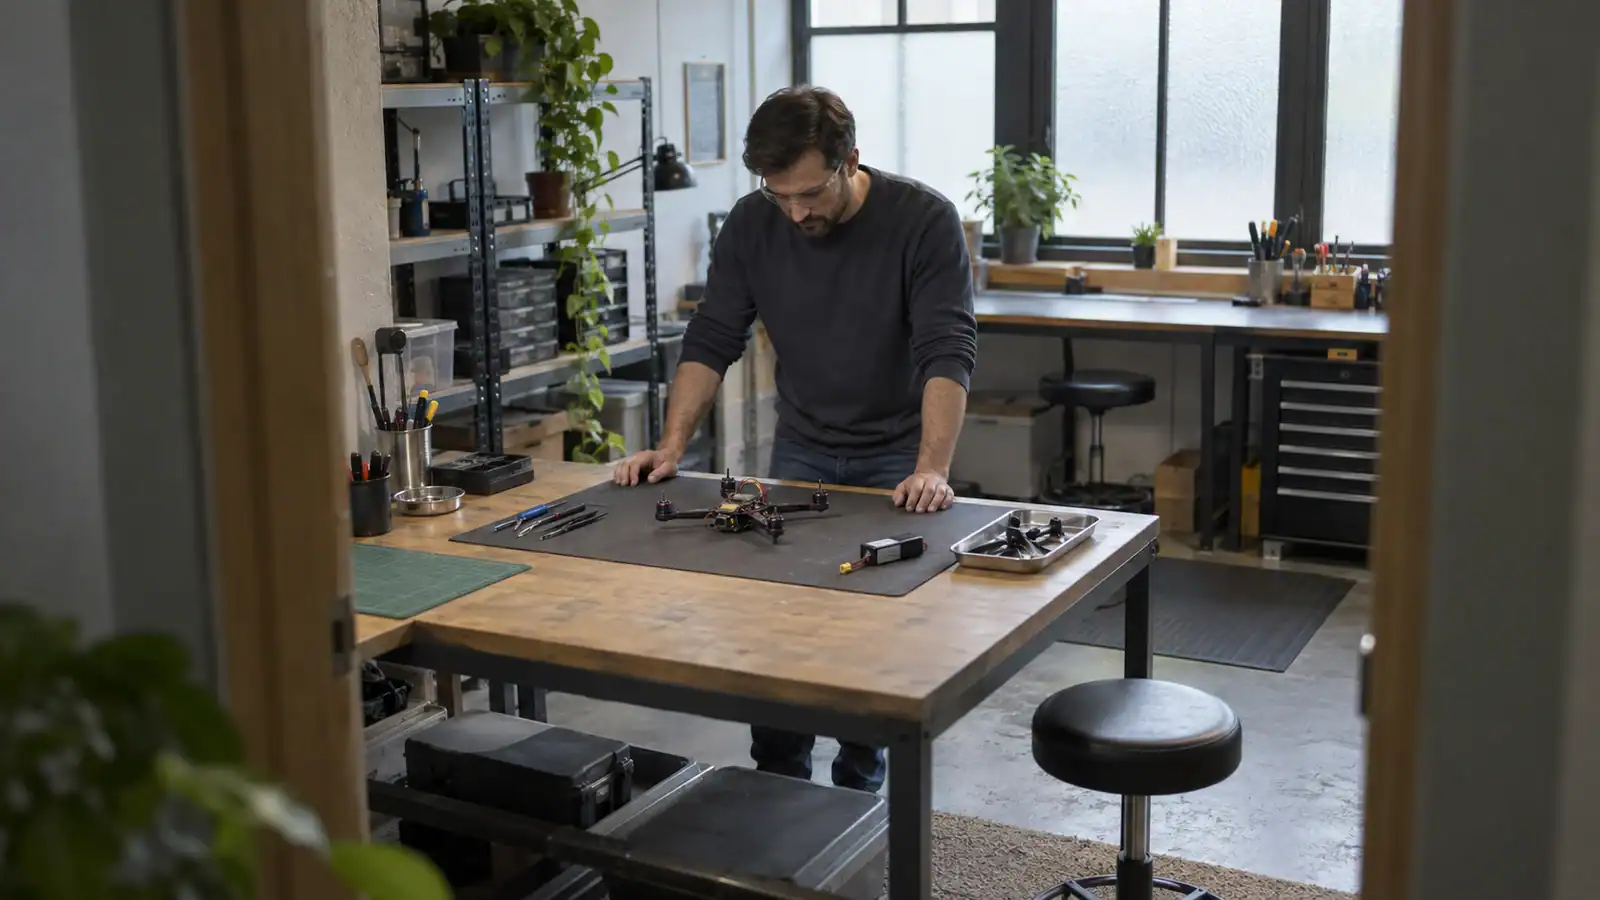
Start SpeedyBee F405 Mini troubleshooting with the propellers removed. Check whether Betaflight detects the gyro, whether an arming flag is blocking the aircraft, and whether each motor responds to an individual motor test. These checks separate three problems that can look alike from the transmitter.
A missing gyro needs a board or firmware investigation. Motors that test correctly but will not arm need an arming check. A single motor that stutters needs its own output, wiring and mechanical inspection. Stop powered testing if a component overheats, smells burnt or shows damage.

Featured gear
SpeedyBee F405 Mini BLS 35A Stack
Compact 20x20 FPV stack combining an F405 Betaflight flight controller, Bluetooth configuration and a 35A BLHeli_S four-in-one ESC. Best for: Compact custom FPV builds requiring flexible peripheral support. Not ideal for: Buyers seeking a…
Compact 20x20 FPV stack combining an F405 Betaflight flight controller, Bluetooth configuration and a 35A BLHeli_S four-in-one ESC.
- Best for
- A feature-rich compact FPV stack for builders comfortable with soldering and Betaflight. Recommend only…
- Skill level
- Intermediate to Advanced
- Product type
- Flight Controllers
- Best for
- A feature-rich compact FPV stack for builders comfortable with soldering and Betaflight. Recommend only…
- Skill level
- Intermediate to Advanced
- Product type
- Flight Controller and ESC Stack
1. Identify the stack and preserve its settings
This checklist covers the F405 Mini and BLS 35A Mini V2 stack. The flight controller reads motion and sends motor commands; the four-in-one electronic speed controller, or ESC, drives the motors. Confirm both board markings before using the SpeedyBee manual, particularly if a previous owner replaced one board.
- Disconnect the battery and USB, then remove every propeller. Check for loose connectors, exposed wire, solder bridges and visible crash damage before reconnecting power.
- Start with a USB data connection. In Betaflight's CLI, record
versionandstatus, then save the output ofdiff all. These record firmware identity, detected sensors, arming flags and settings changed from defaults. - Write down when the problem began: after a crash, soldering, a firmware update or a settings change. Change one thing at a time so you can identify what affected the symptom.
Use the Betaflight CLI reference for those commands. Do not paste a configuration backup into a different firmware version. Also avoid the Setup tab's Reset Settings button as an opening diagnostic: Betaflight warns that it clears the configuration rather than restoring a finished aircraft's factory setup.
2. Separate a missing gyro from incorrect orientation
The manufacturer's F405 Mini specifications identify an ICM42688P gyro and the firmware target SPEEDYBEEF405MINI. A board with an F405 processor is not automatically the same target.
If status reports NOGYRO, compare the installed target with the board identity. Betaflight's arming guidance lists a wrong target, firmware trouble and hardware failure as possible causes. Keep the aircraft grounded. Repeated accelerometer calibration is not a repair for an undetected gyro.
If the gyro is detected, use the Setup tab's live preview. With motors stopped, tilt and rotate the aircraft on each axis and compare the displayed movement. Correct board alignment if the response disagrees with the actual mounting. Calibrate the accelerometer on a level surface when required for self-leveling functions; that is a separate task from establishing gyro detection.
Reflash only after preserving the existing configuration and confirming the exact target. Apply the board-specific custom defaults when prompted, following the instructions for that firmware release. The Mini requires a computer connection for flight-controller firmware flashing; Bluetooth configuration does not provide wireless FC flashing. If the app connection itself fails, follow our F405 Mini Bluetooth troubleshooting guide before returning to the sensor checks. At the September 9, 2026 check, the official 2026.6.1 release was marked Latest. That label alone does not establish the correct build or configuration for your aircraft. Follow the release instructions and verify board support before changing versions.
If a correctly identified board still reports no gyro after the appropriate firmware recovery, stop and give support the firmware identity and status output. Do not guess sensor-driver overrides.
3. Read the arming flag before blaming the motors
Use the flag name shown by your installed firmware. The official flag table explains the conditions; numeric beep codes depend on firmware version.
RXLOSSorRX_FAILSAFE: establish a valid receiver link and confirm stick response before checking the arm switch.THROTTLE: lower the throttle and verify its displayed input.CALIB: leave the aircraft still and allow sensor calibration to finish.MSPorCLI: a configuration connection can prevent normal arming. This does not diagnose a failed ESC.RPMFILTERorDSHOT_TELEM: investigate missing motor-speed telemetry before attempting flight.
Resolve the cause of the flag. Do not disable arming protections to prove that the aircraft can spin its motors.
4. Test individual motors, then inspect the failing path
Follow Betaflight's Motors tab procedure: remove all props, connect the battery to power the ESC, and use individual controls at low output. USB connectivity alone does not establish that the ESC has motor power. Keep hands and loose objects clear; return each control to zero before moving on.
Check each motor against the displayed position and rotation direction. The props-in or props-out selection must agree with actual motor rotation and the propellers fitted later. Do not infer motor order from the way the stack looks in the frame.
All four motors stay still
Disconnect power and inspect the battery connection and FC-to-ESC harness against the exact manual. Reconnect a loose supplied connector only after checking it for damage. A matching connector shape does not establish a replacement cable's pinout. Confirm the configured motor protocol against the BLS 35A Mini V2 specifications, which list DShot300 and DShot600.
If the fault started after changing battery cell count, motors or propellers, revisit the complete propulsion combination before another flight. Our F405 Mini 4S versus 6S guide explains the motor-matching checks; the stack voltage range alone cannot establish that a motor and propeller combination is suitable.
One motor stutters or fails to start
Stop the test and disconnect battery and USB. Inspect that motor's leads and joints, look for debris, and check whether its bell turns freely. If you already read the ESC settings under the manufacturer's powered connection procedure, record whether that channel appeared. These observations help localize the fault, but do not by themselves prove which component failed. If inspection does not reveal a safe, obvious correction, have a qualified repairer isolate the motor and ESC channel before buying a replacement.
SpeedyBee recommends the supplied low-ESR capacitor. Check its installation against the manual rather than adding random capacitance. For the original stack's physical and electrical limits, see our F405 Mini stack review.
5. Match RPM filtering to the ESC firmware
DShot motor control and bidirectional DShot are different capabilities. The latter returns motor-speed data to the flight controller so RPM filtering can track motor-related noise. Enabling the option in Betaflight does not add the feature to unsupported ESC firmware.
The Mini V2 manual identifies BLHeli_S firmware and the J-H-40 ESC target, and describes Bluejay as an option for bidirectional DShot. Read the actual installed firmware and target first. If the detected identity differs, stop and resolve the discrepancy rather than forcing that target. This is ESC firmware, separate from the flight controller's SPEEDYBEEF405MINI target.
Use the RPM filtering guide to verify the whole configuration. With compatible firmware and the ESC powered, check telemetry from all four motors. Missing telemetry on USB-only power is not a useful failure diagnosis. If telemetry remains invalid under the correct test conditions, keep the aircraft grounded and investigate the affected path. Do not suppress the warning while leaving the filters dependent on data they are not receiving.
6. Treat bench spin-up, takeoff flips and flight twitches differently
Motors accelerating while an aircraft is armed without props can result from the controller trying to correct movement it cannot produce. Betaflight's troubleshooting guide explains this behavior. Disarm; use the individual motor test instead of holding the aircraft and adding throttle.
A flip at takeoff requires rechecking motor order, rotation, propeller orientation and board alignment. Keep runaway protection enabled. For twitches during flight, inspect for loose mechanical parts and anything contacting the gyro or loading the flight controller. Start with those checks before changing PID gains or filters. A twitch alone cannot establish that the gyro is defective.
End owner-level troubleshooting when you find visible damage, abnormal heating, persistent gyro loss, an unreadable ESC channel or a fault that survives the relevant configuration checks. Give the repairer photos of both boards and their wiring, firmware identities, arming flags, the affected motor position and any existing Blackbox log. Do not fly an unstable aircraft just to collect another log.
Resolve the fault before returning to flight
Resume flight preparation only after sensor response, receiver inputs, motor mapping and required telemetry agree. A successful propeller-free bench check cannot establish performance under propeller load. If the failing component has not been isolated, replacement shopping is premature.
Sources
- SpeedyBee F405 Mini stack manual: board pairing, connections, capacitor guidance and ESC firmware identity.
- SpeedyBee F405 Mini specifications: gyro, firmware target and wireless limitations.
- Betaflight CLI reference: status, version and configuration backup commands.
- Betaflight Setup tab: sensor preview, accelerometer calibration and reset behavior.
- Betaflight arming sequence and safety: arming-prevention flags and gyro-detection causes.
- Betaflight Motors tab: safe motor testing, mapping and telemetry checks.
- Betaflight DShot RPM filtering: bidirectional telemetry and filtering requirements.
- Betaflight troubleshooting: bench acceleration, takeoff flips and mechanical causes of twitches.
- Betaflight 2026.6.1 release: current published release checked for this guide.
Last checked: September 9, 2026.